
Digital traction with Japanese finger sleeves
Our project's objective is to design a device that creates stability in the hand and wrist for surguries/casting.
Project Overview
The objective of this project is to create a digital traction device using finger traps that precisely pulls the patient's hand, wrist, and forearm into a comfortable, neutral position while holding a stable static load about 1/10th of the patient’s weight. To be feasible for Idrissa Pouye Hospital, the device must be portable and usable in both the plaster casting room and the operating room. This requires a compact device that can be transported easily between spaces and provides unobstructed access to the forearm for casting and arthroscopy. It must tolerate routine sterilization without degradation and maintain its mechanical material properties. In addition, the design must be simple enough to fabricate, assemble, and repair using materials and processes available in or near Dakar so that the hospital can maintain a reliable inventory even as individual devices are lost or damaged over time.
Team Picture
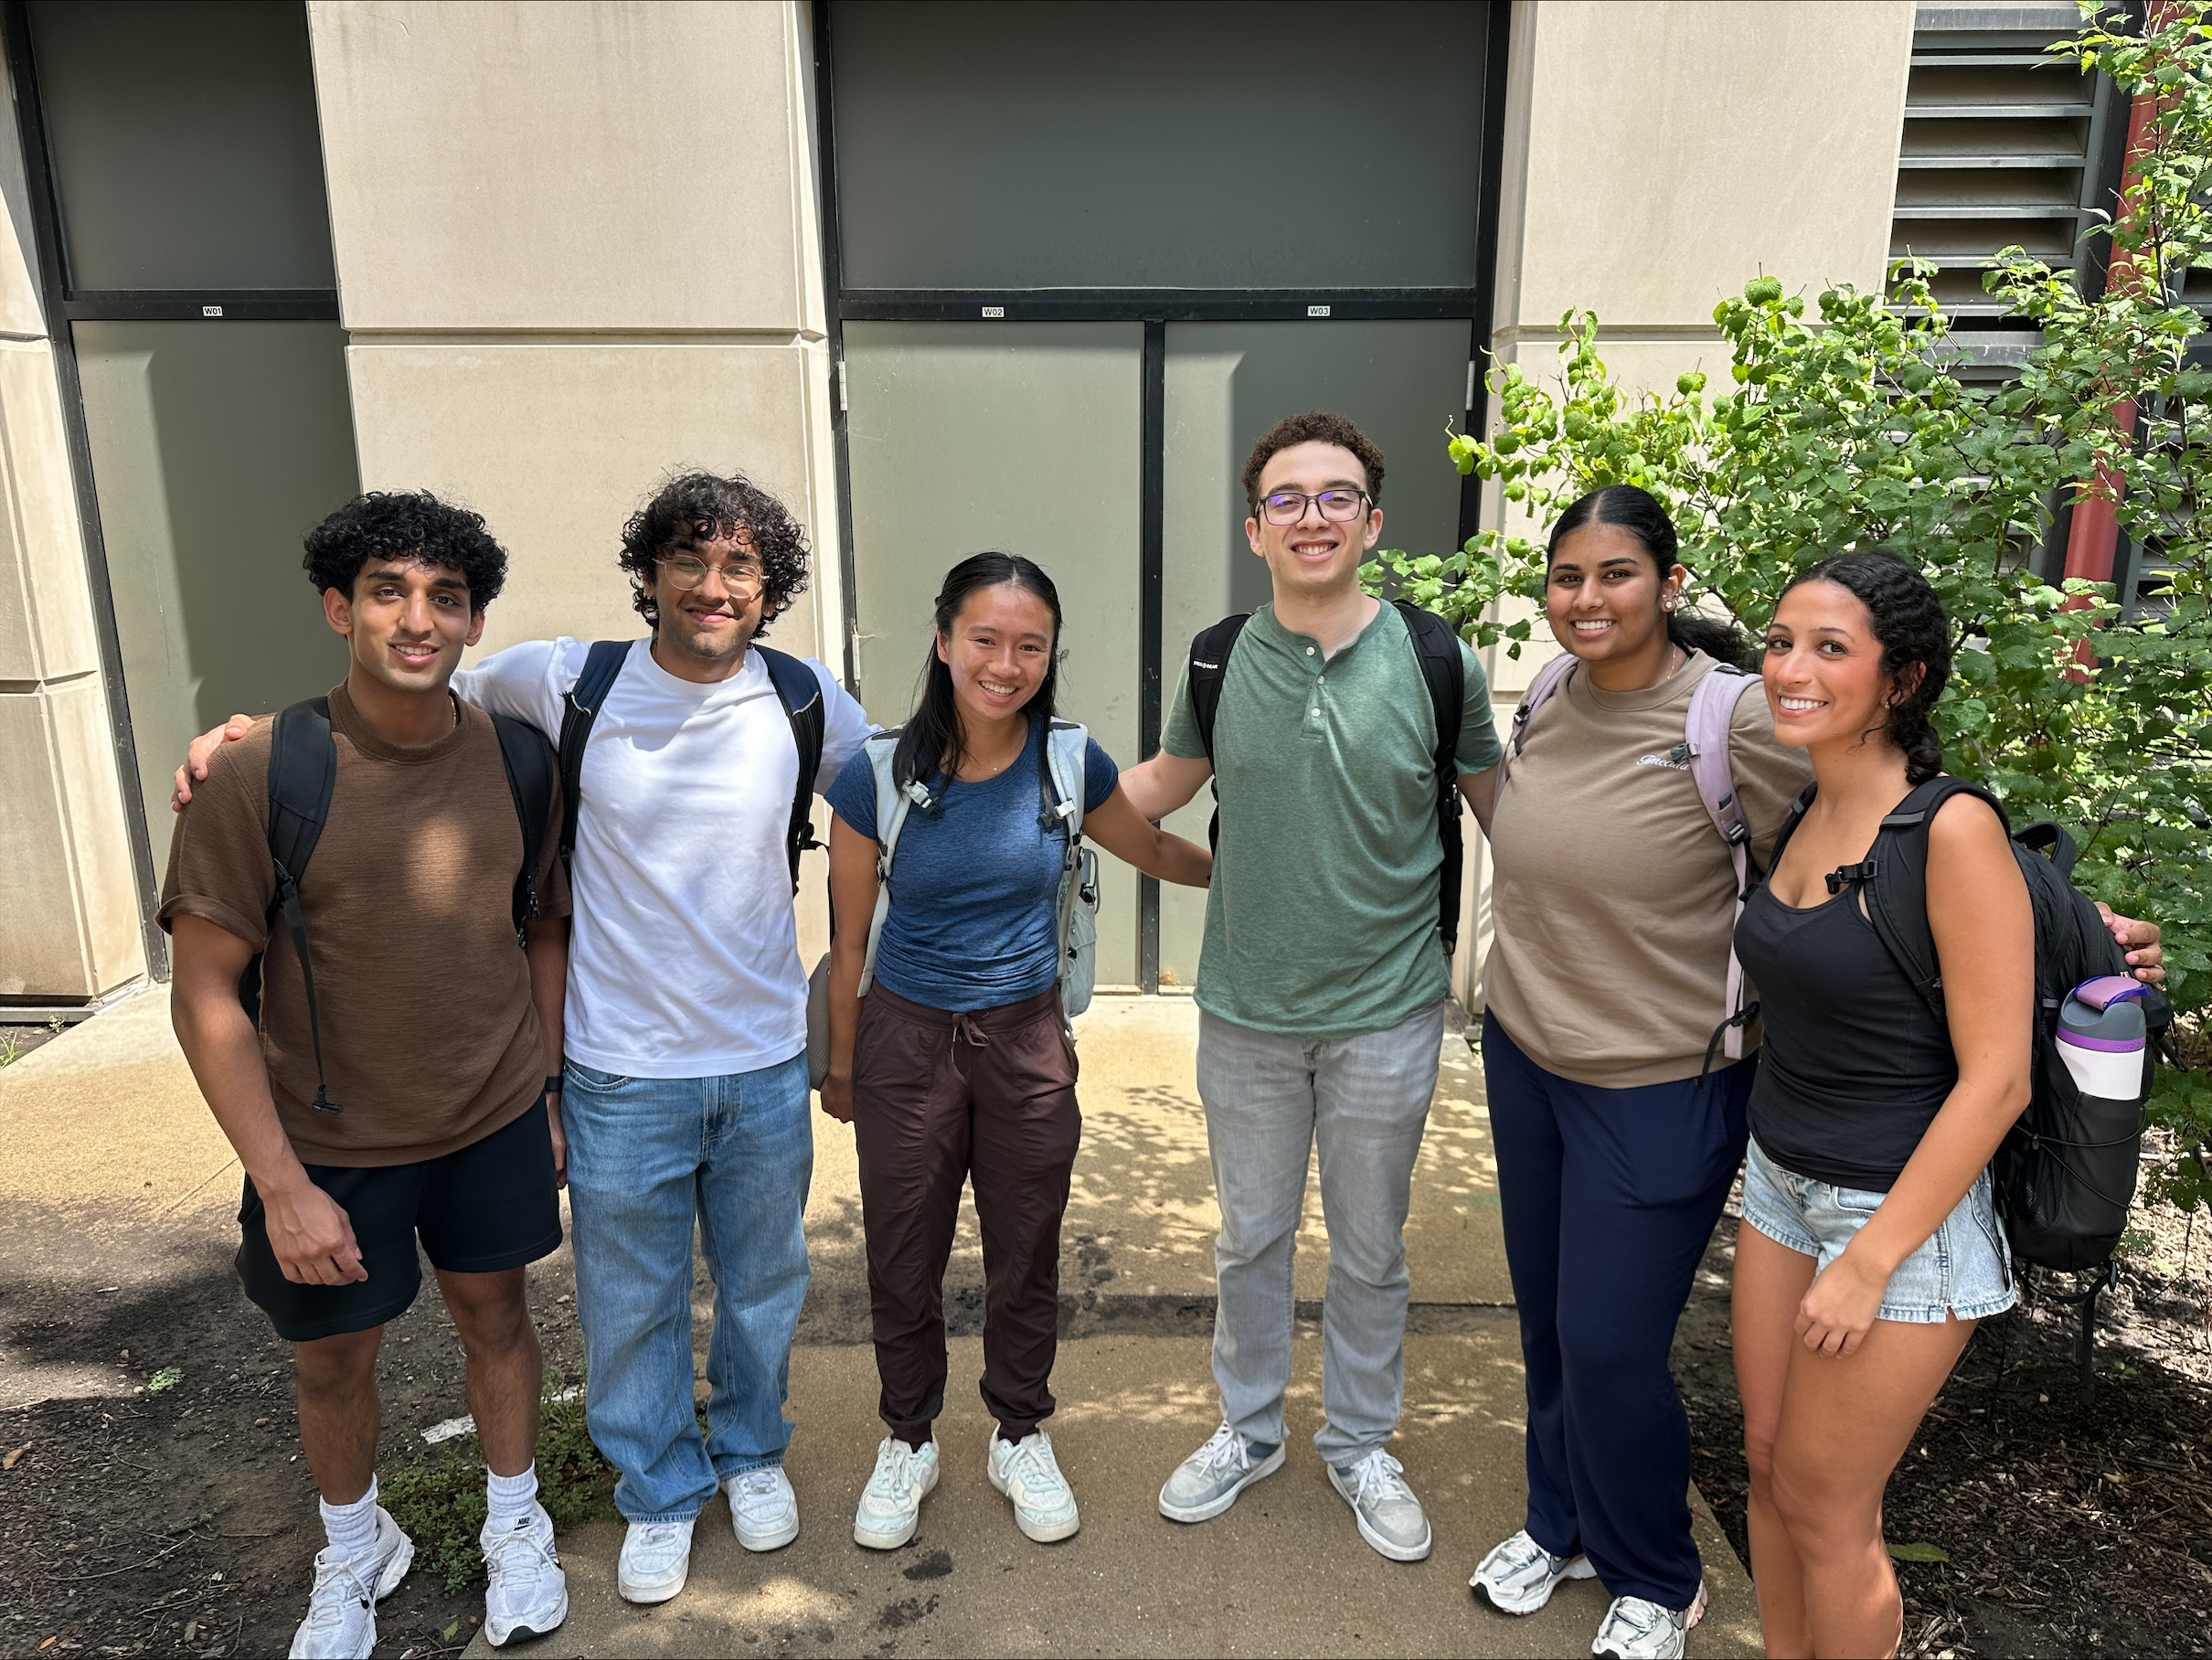
File
- PDS (September 18, 2026)
Progress Reports
- Week 4 (October 1, 2026)
- Week 3 (September 24, 2026)
- Week 2 (September 17, 2026)
- Week 1 (September 10, 2026)
Contact Information
Team Members
- Amy Dang - Co-Team Leader
- Sean Carey - Co-Team Leader
- Anshpreet Sohal - Communicator
- Patricia Prakasam - BSAC
- Henna Razeq - BWIG
- Karthik Anem - BPAG
Advisor and Client
- Prof. Randolph Ashton - Advisor
- Mr. Pape Samb - Client
- Srihari Gopalan - Alternate Contact
- Prof. Mohamed Soumah - Alternate Contact
Related Projects
- Fall 2026: Digital traction with Japanese finger sleeves
- Fall 2025: Digital traction with Japanese finger sleeves