
3D camera for real-time surgical planning
This project has been secured to protect intellectual property.
Login for More InformationA camera-based navigation system that aligns a 3D scan of the patient's head to their MRI or CT, then overlays the planned surgical entry point onto the live camera view in real time.
Project Overview
The 3D Camera for Real-Time Surgical Planning team (Surgi_Cam) is developing a camera-based surgical navigation system that translates a surgeon-defined trajectory from preoperative 3D MRI data to the patient’s physical anatomy in the operating room. Given a defined intracranial target and entry point in MRI coordinates, Surgi_Cam aims to register the MRI to the patient’s head and identify the corresponding physical entry location and trajectory orientation with sufficient accuracy for neurosurgical guidance. By simplifying image-to-patient registration and reducing dependence on cumbersome stereotactic localization and setup procedures, the system aims to improve procedural accuracy, efficiency, and accessibility while reducing operating-room setup time.
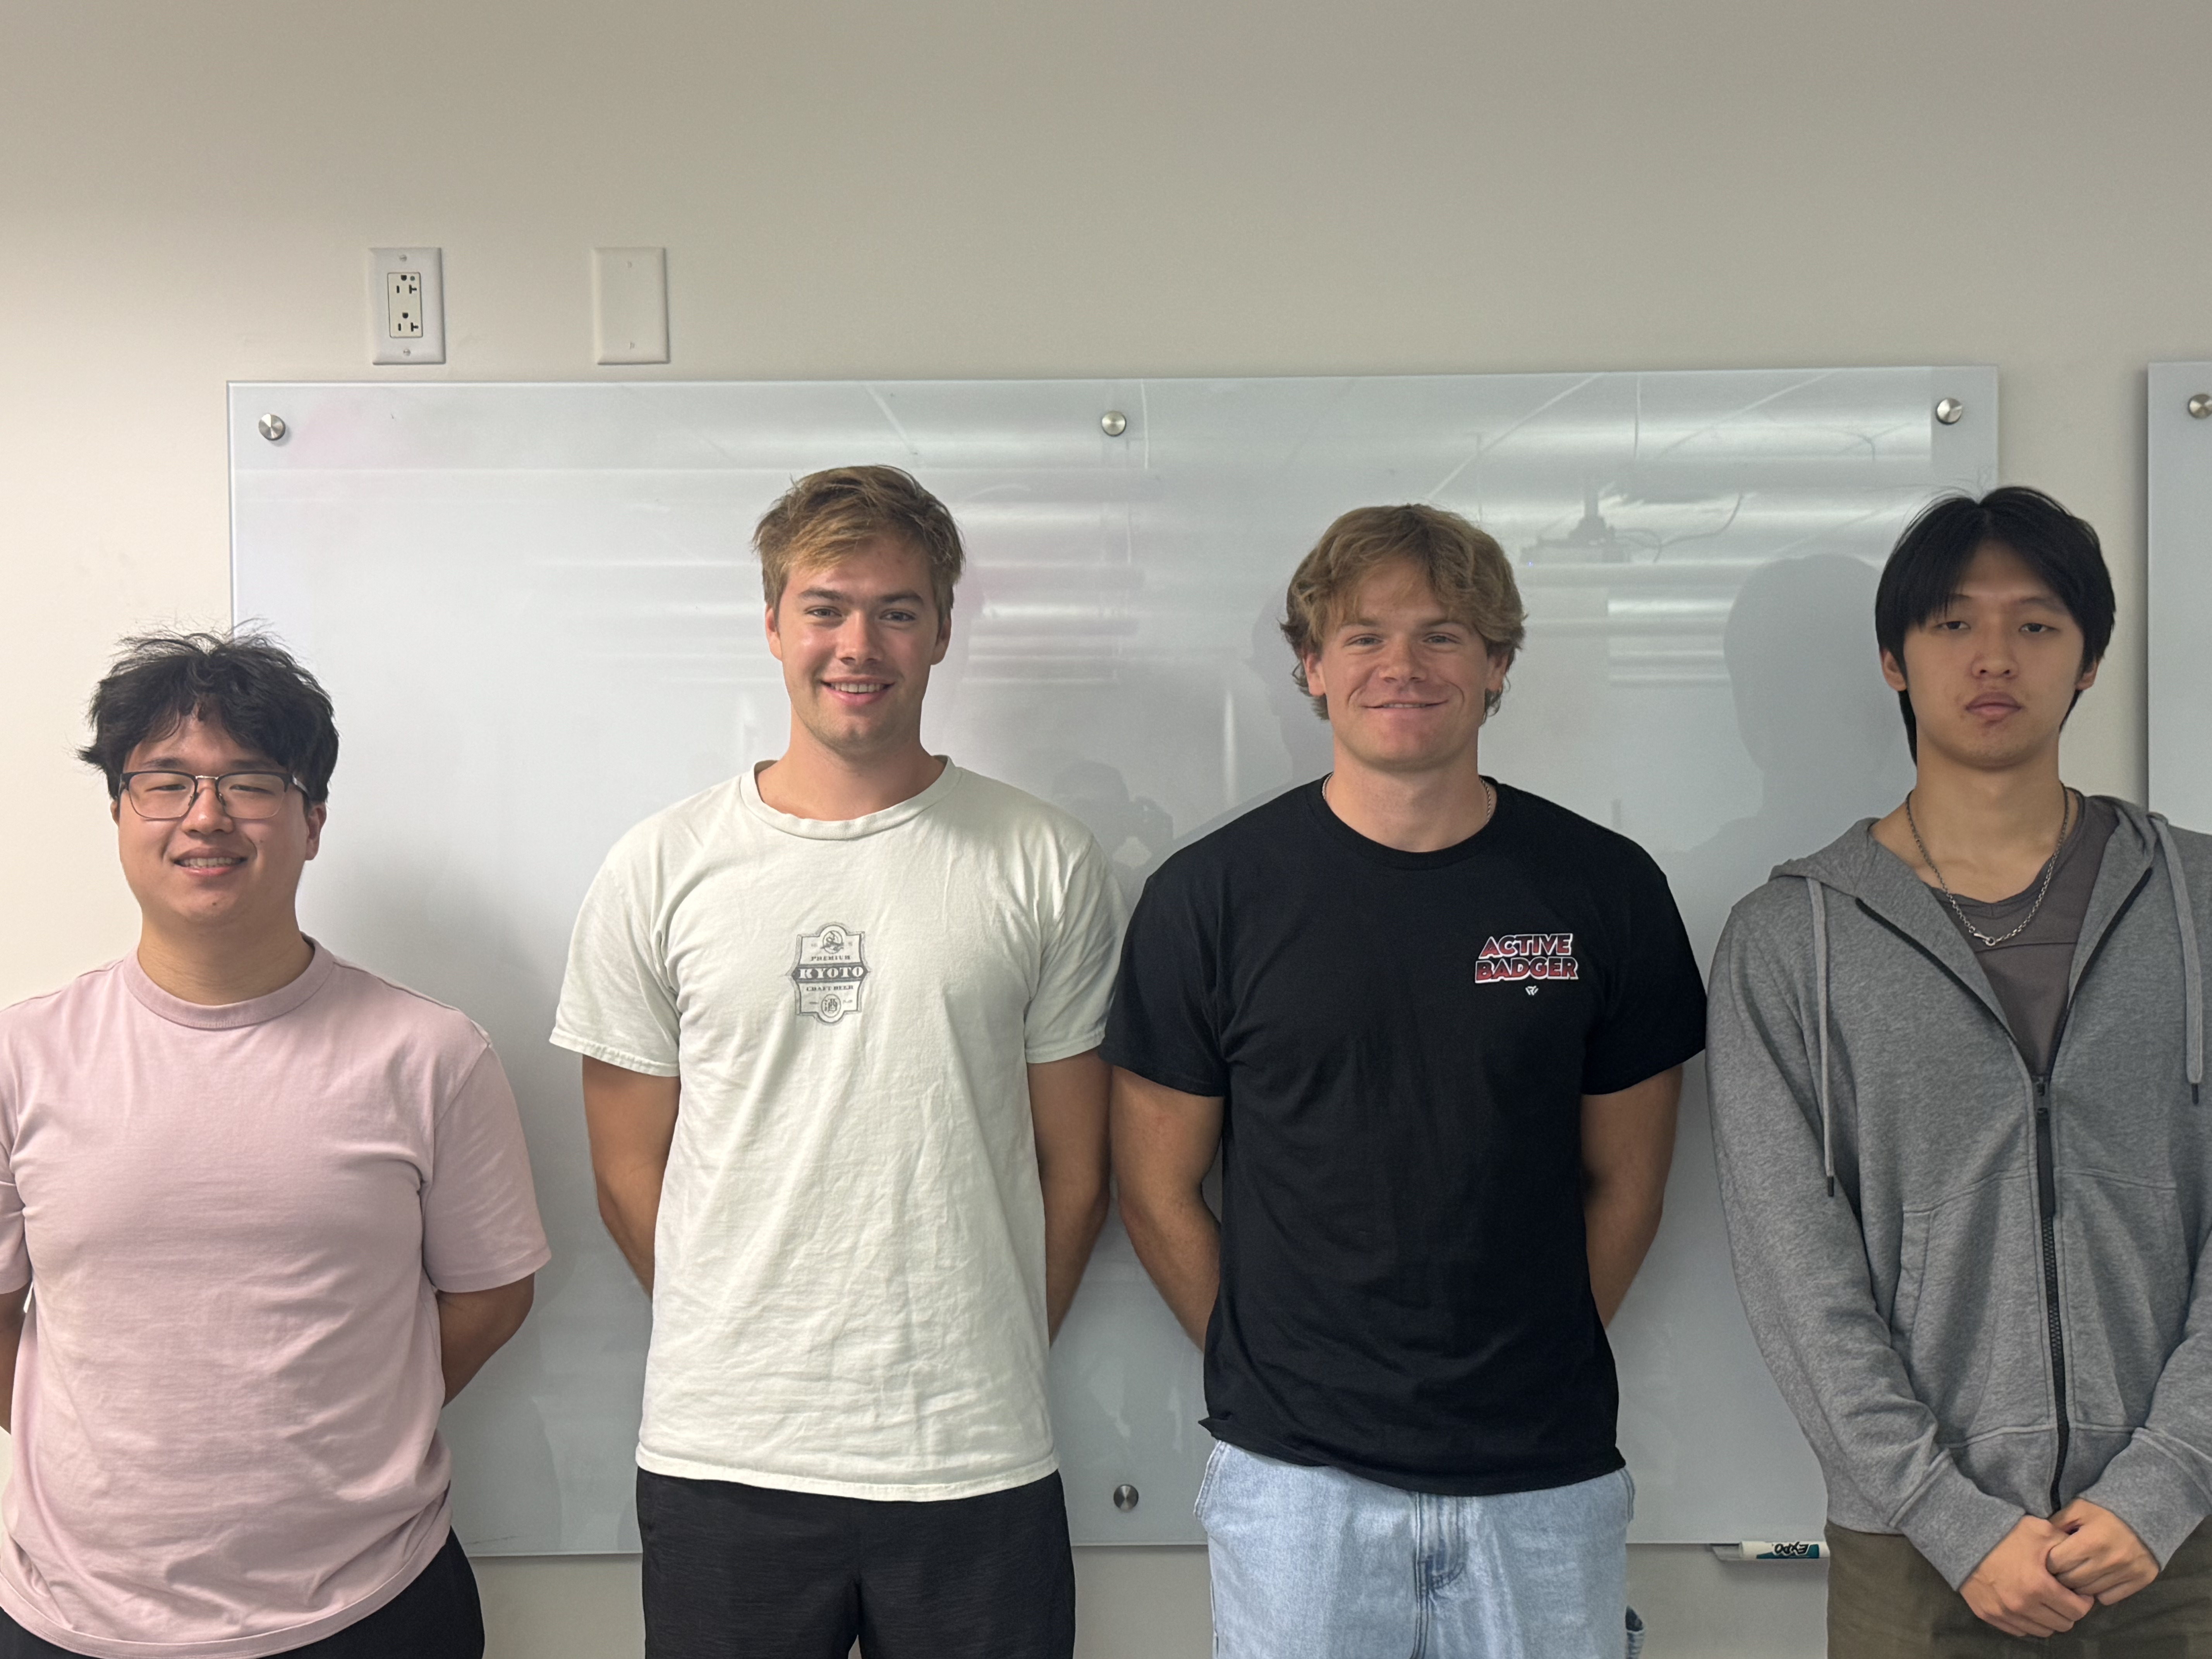
Team Picture
Contact Information
Team Members
- Enson Zheng - Team Leader
- Kevin Zhang - Communicator
- Ruffin Bryant - BSAC & BPAG
- Noah Kalthoff - BWIG
Advisor and Client
- Prof. Amit Nimunkar - Advisor
- Steven Oakes - Client
- Prof. Walter Block - Alternate Contact